Publications
Academic Publications
2020

2019
-
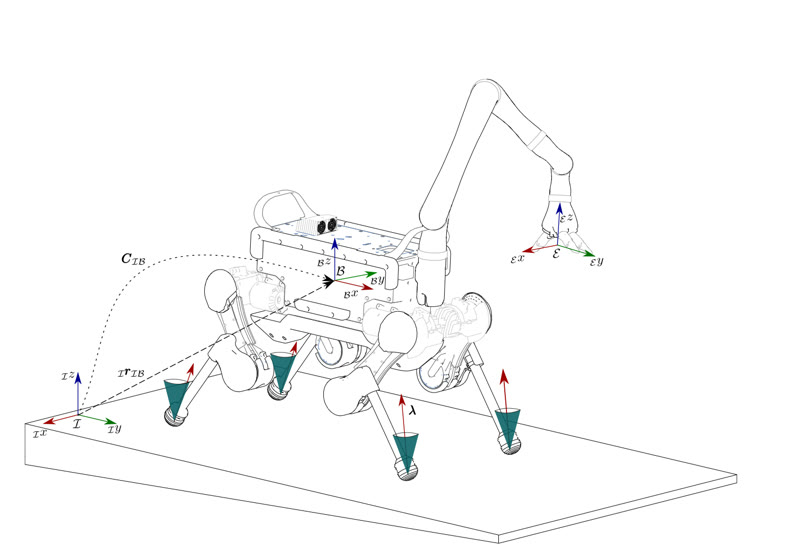 Optimization-based planning and control for multi-limbed walking robotsETH Zurich, 2019


2018
-
 Efficient Gait Selection for Quadrupedal Robots on the Moon and MarsIn 14th International Symposium on Artificial Intelligence, Robotics and Automation in Space (i-SAIRAS 2018), Oct 2018


2017
-
 Dynamic locomotion and whole-body control for quadrupedal robotsIn International Conference on Intelligent Robots and Systems (IROS), 2017 IEEE/RSJ, Jan 2017
-
 Quadrupedal locomotion using trajectory optimization and hierarchical whole body controlIn International Conference on Robotics and Automation (ICRA), 2017 IEEE, Jan 2017


2016
-
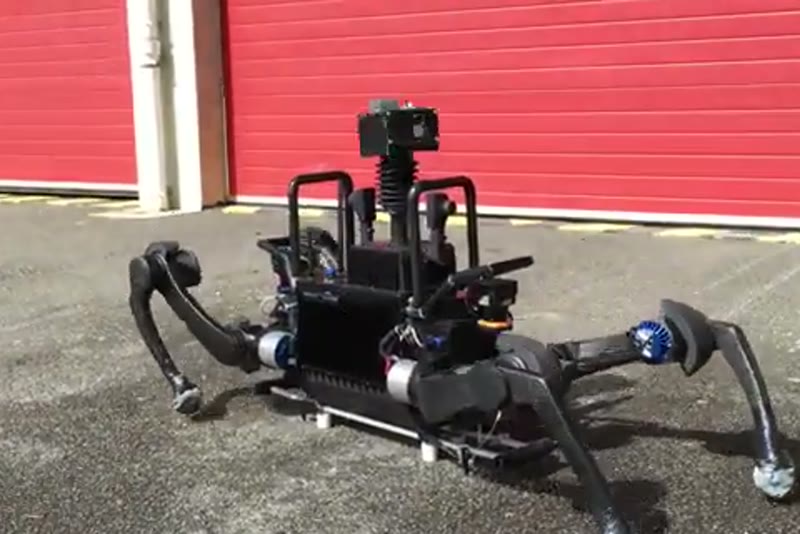 Free gait—An architecture for the versatile control of legged robotsIn International Conference on Humanoid Robots (Humanoids), 2016 IEEE-RAS 16th, Jan 2016
-
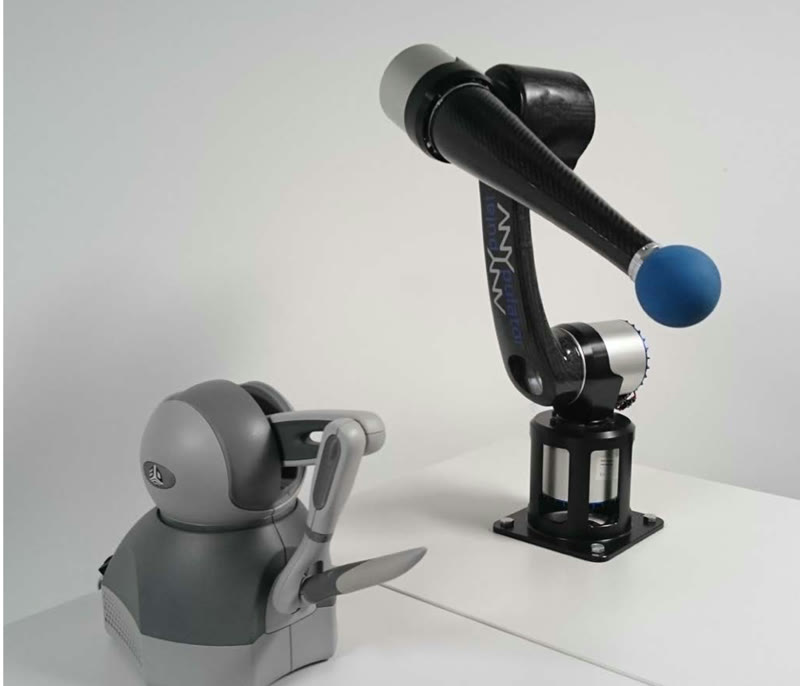 ANYpulator: Design and control of a safe robotic armIn Intelligent Robots and Systems (IROS), 2016 IEEE/RSJ International Conference on, Jan 2016
-
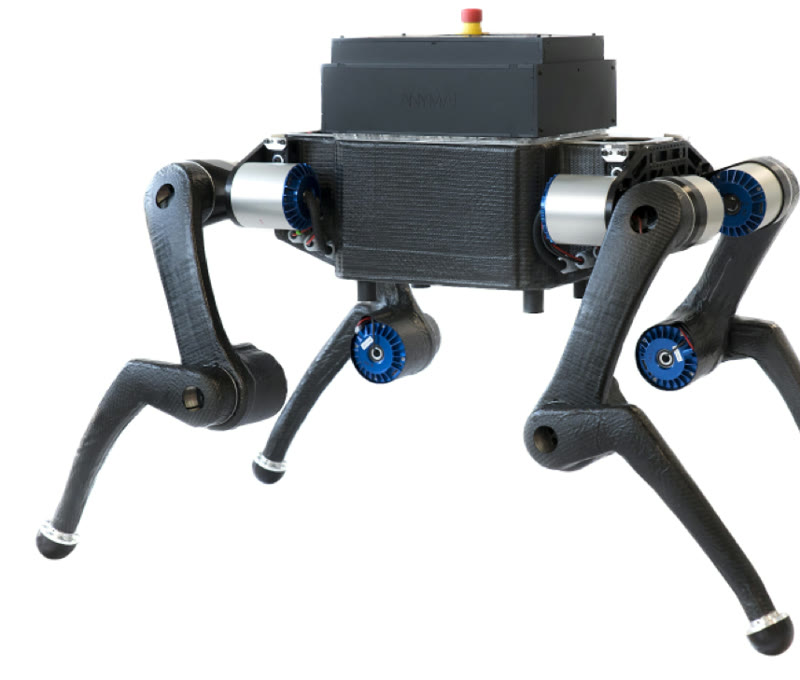 Probabilistic foot contact estimation by fusing information from dynamics and differential/forward kinematicsIn International Conference on Intelligent Robots and Systems (IROS), 2016 IEEE/RSJ, Jan 2016
-
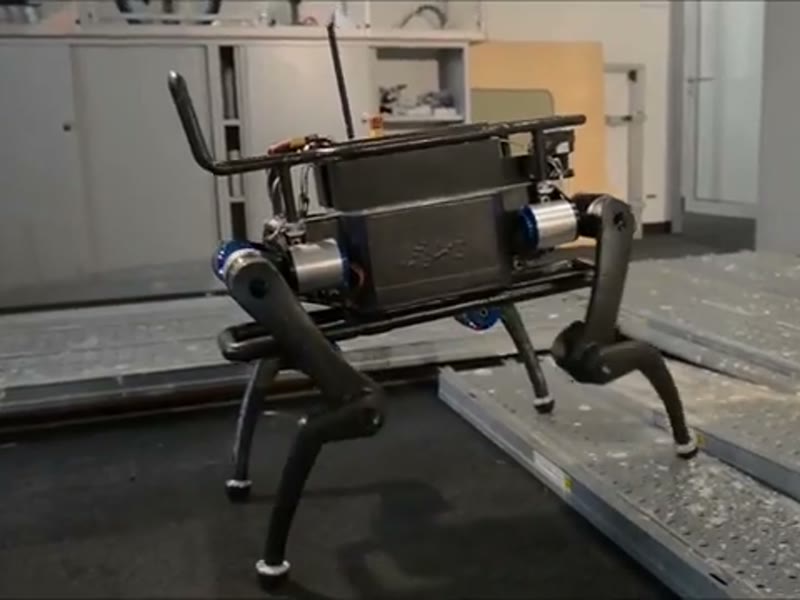 Anymal-a highly mobile and dynamic quadrupedal robotIn 2016 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Jan 2016
-
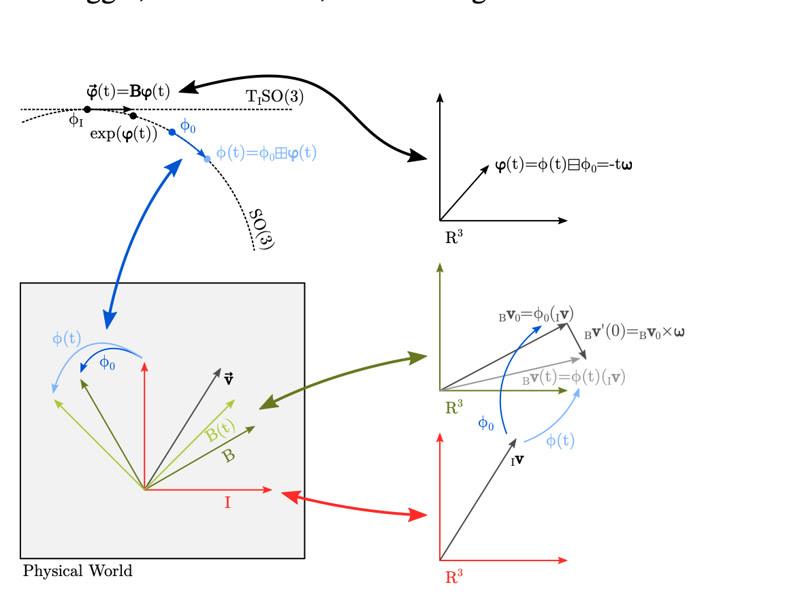 A Primer on the Differential Calculus of 3D OrientationsCoRR, Jan 2016
-
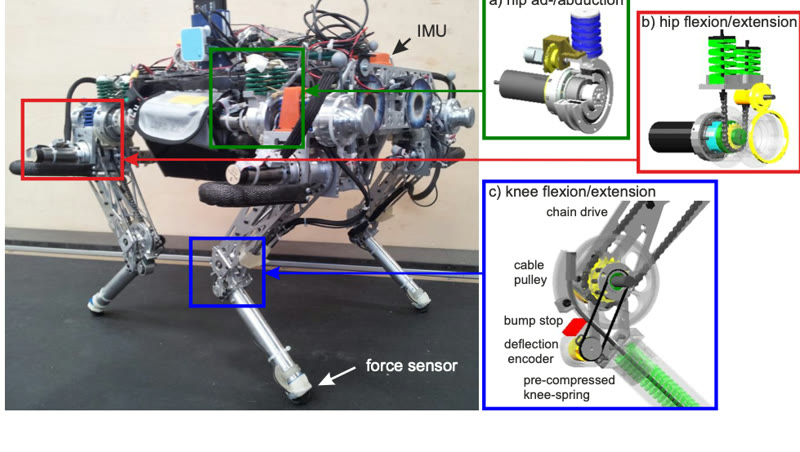 Practice makes perfect: An optimization-based approach to controlling agile motions for a quadruped robotIEEE Robotics & Automation Magazine, Jan 2016


2015
-
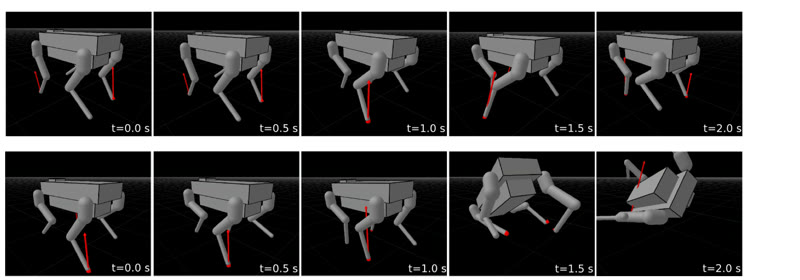 Direct state-to-action mapping for high DOF robots using ELMIn 2015 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Jan 2015


Patents
2025
-
 Nonlinear trajectory optimization for robotic devicesMay 2025US Patent App. 18/938,800

2024
-
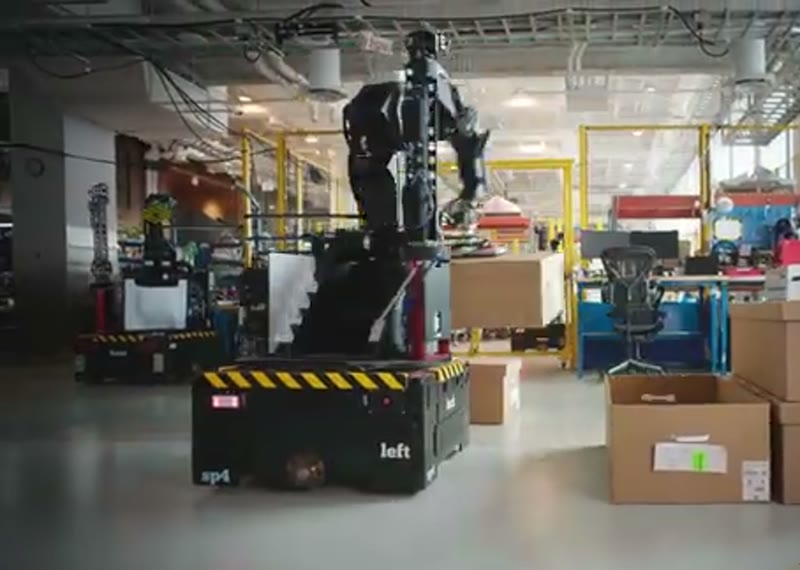 Nonlinear trajectory optimization for robotic devicesDec 2024US Patent 12,168,300
-
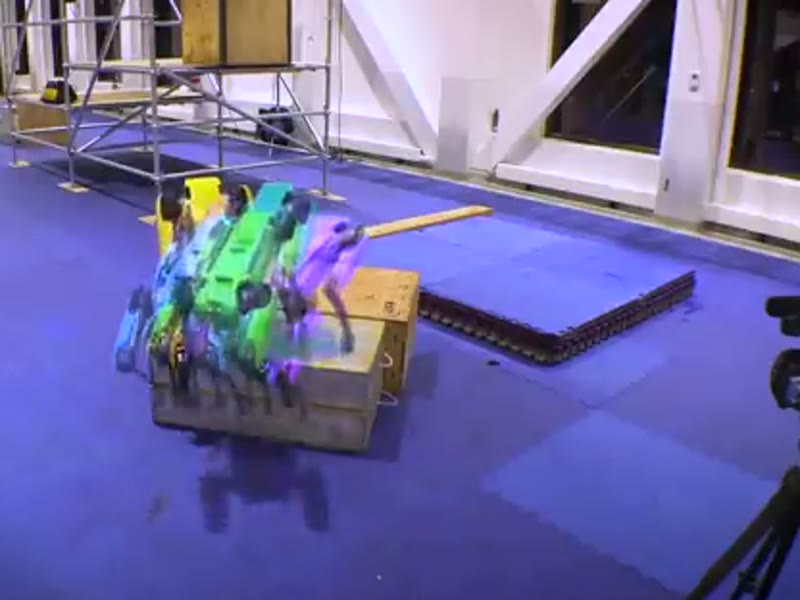 Object climbing by legged robots using training objectsJun 2024US Patent App. 18/537,269


2023
-
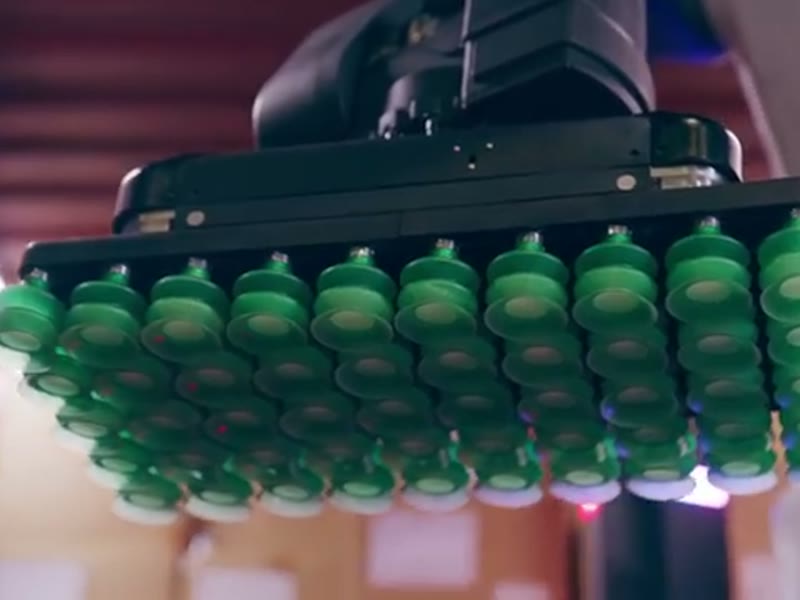 Systems and methods for grasp planning for a robotic manipulatorJun 2023US Patent App. 17/988,982
